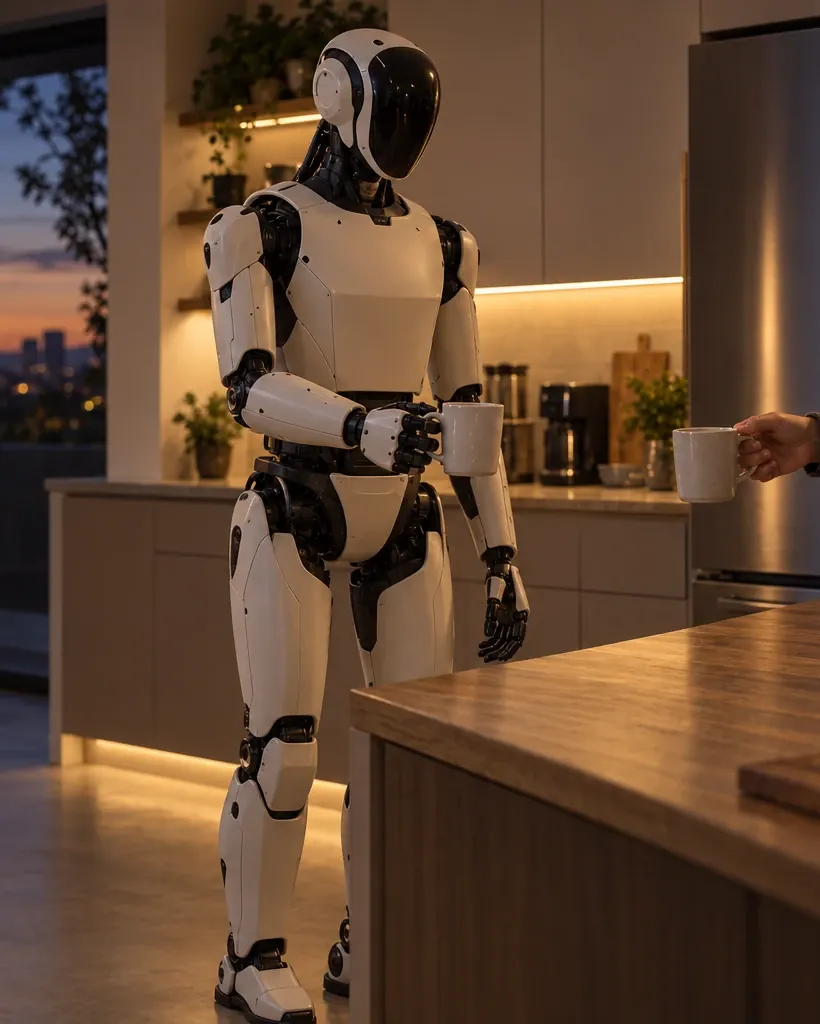
A humanoid robot in a home kitchen at dusk, holding a mug as a person hands over another.

NovaCrest Robotics

Building the infrastructure robots learn from

Robots need experience of real places, objects and tasks. We collect it today through first-person recordings of people at work, and we are building one route from a robotics team’s specification to delivered, evaluated data.

Illustration

Why robotics

How robots got here

Six stages took robots from taught motions to general skills, and each one still runs today. The next stage depends on experience of the real world.

Skip the story
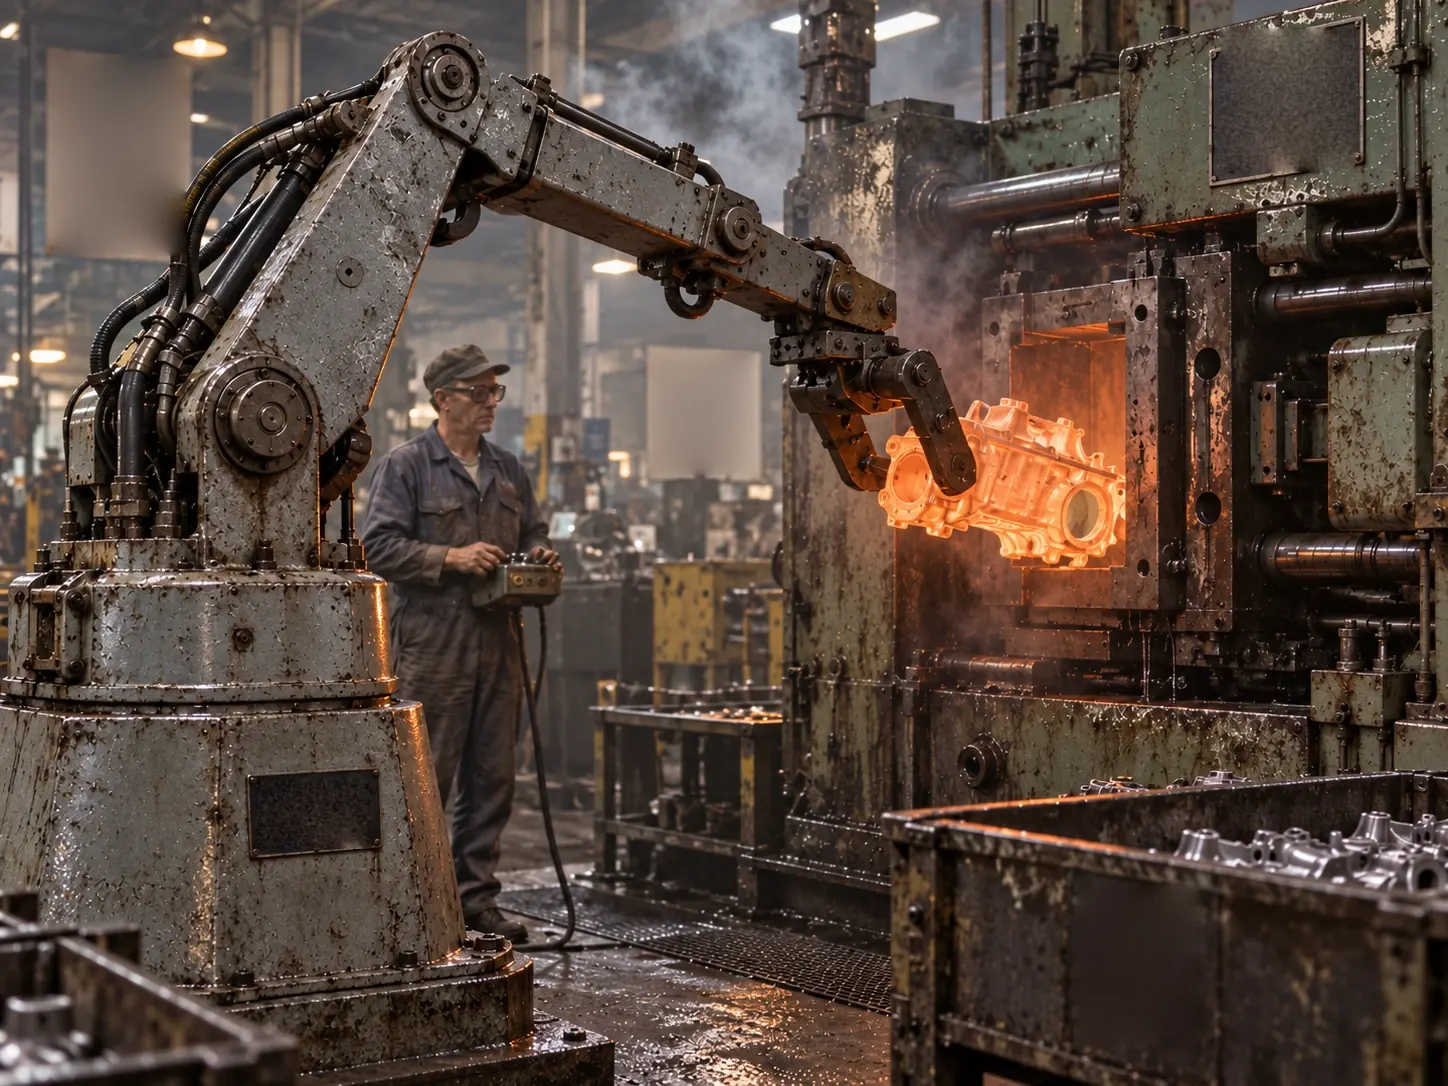
  1. A 1960s hydraulic robot arm lifts a glowing hot casting from a die-casting machine while an operator watches.
    Illustration

    01Programmed · 1961

    Machines that repeat

    Unimate starts work at a General Motors plant, replaying positions an operator taught it, one hot casting at a time.

    Source: IEEE Robots Guide

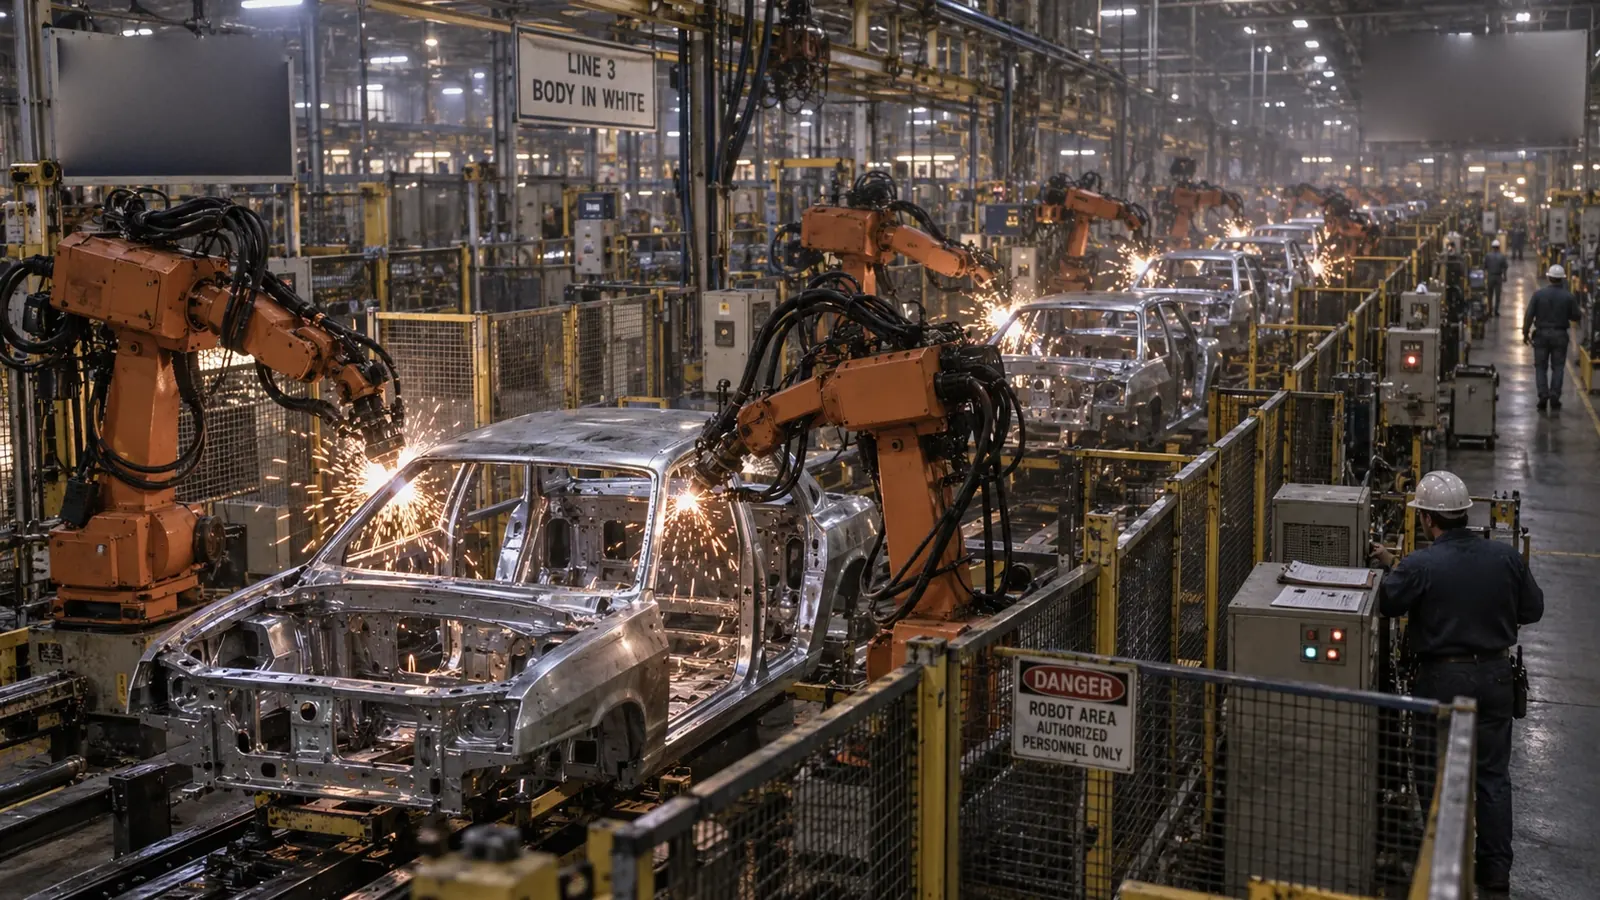
  2. Rows of orange six-axis robot arms spot-weld bare car bodies on a production line, with sparks flying.
    Illustration

    02Scaled · 1970s onwards

    Factories at scale

    Six-axis arms take over welding and assembly in fenced cells. Factories installed about 542,000 industrial robots in 2024 alone.

    Sources: KUKA, IFR

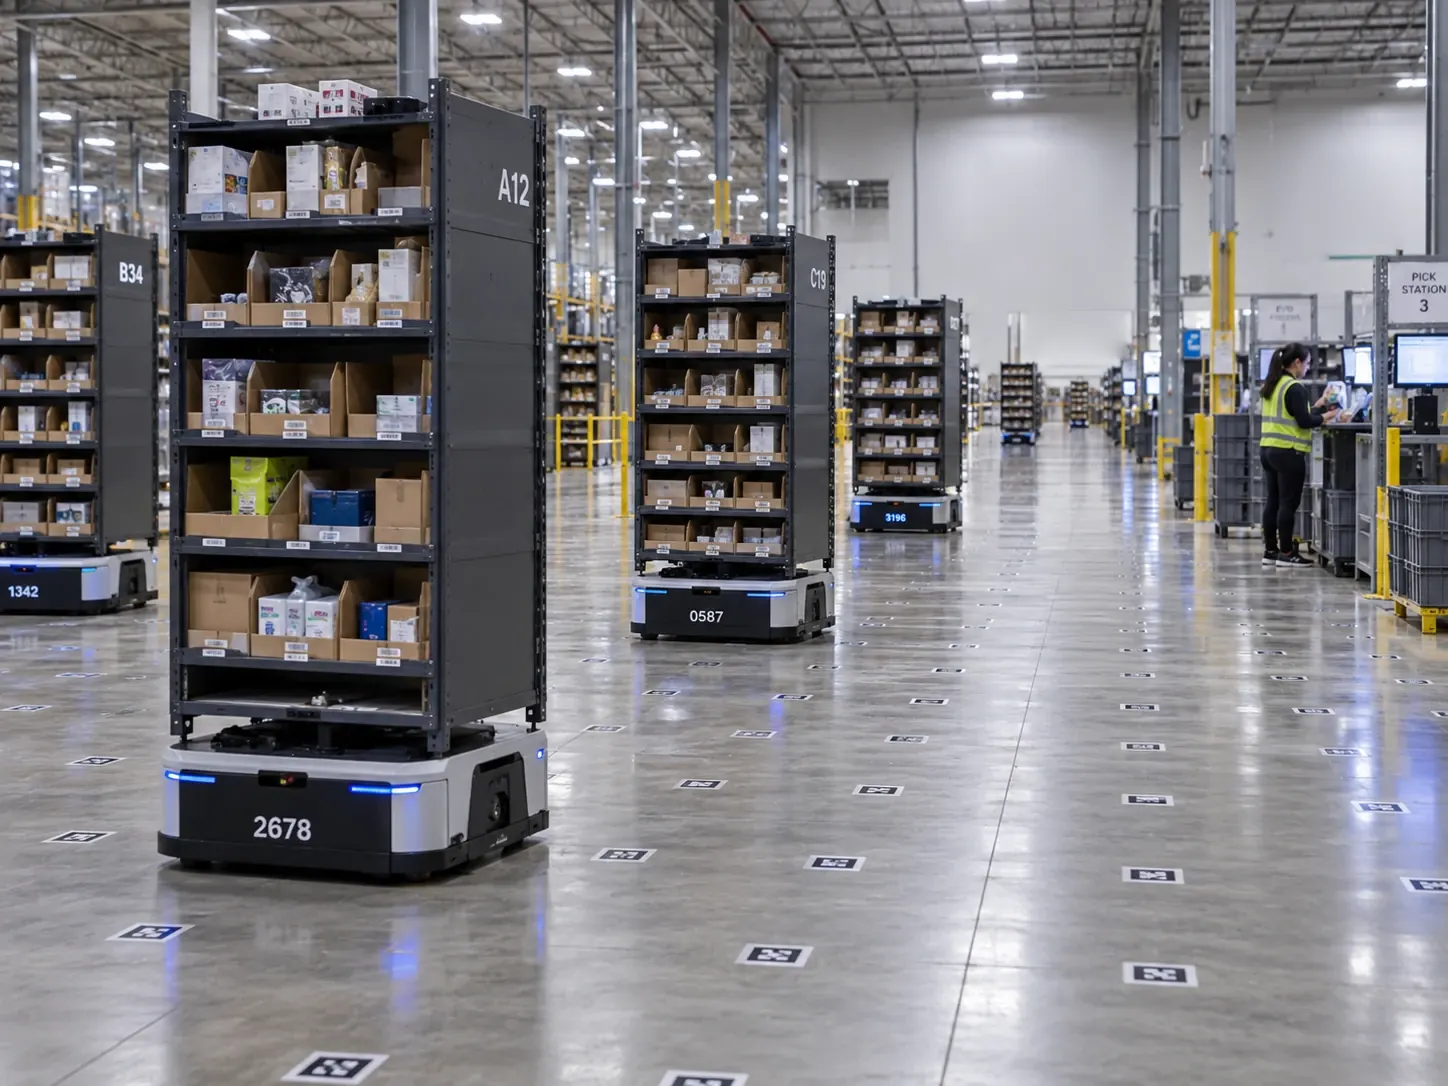
  3. Mobile robots carry tall shelves of goods across a warehouse floor marked with navigation codes, towards a worker at a pick station.
    Illustration

    03Mobile · 2000s

    Robots that move

    Warehouse robots carry whole shelves to people by reading markers on the floor. Amazon bought Kiva in 2012 and reported its one millionth robot in 2025.

    Sources: Amazon, About Amazon

  4. Diagram, not to scale

    04Learning · 2012 to 2021

    Robots that learn from data

    In 2016, Google’s robot arms made more than 800,000 grasp attempts and improved with experience. In 2019, a hand trained in simulation solved a Rubik’s Cube.

    Sources: Levine et al., OpenAI

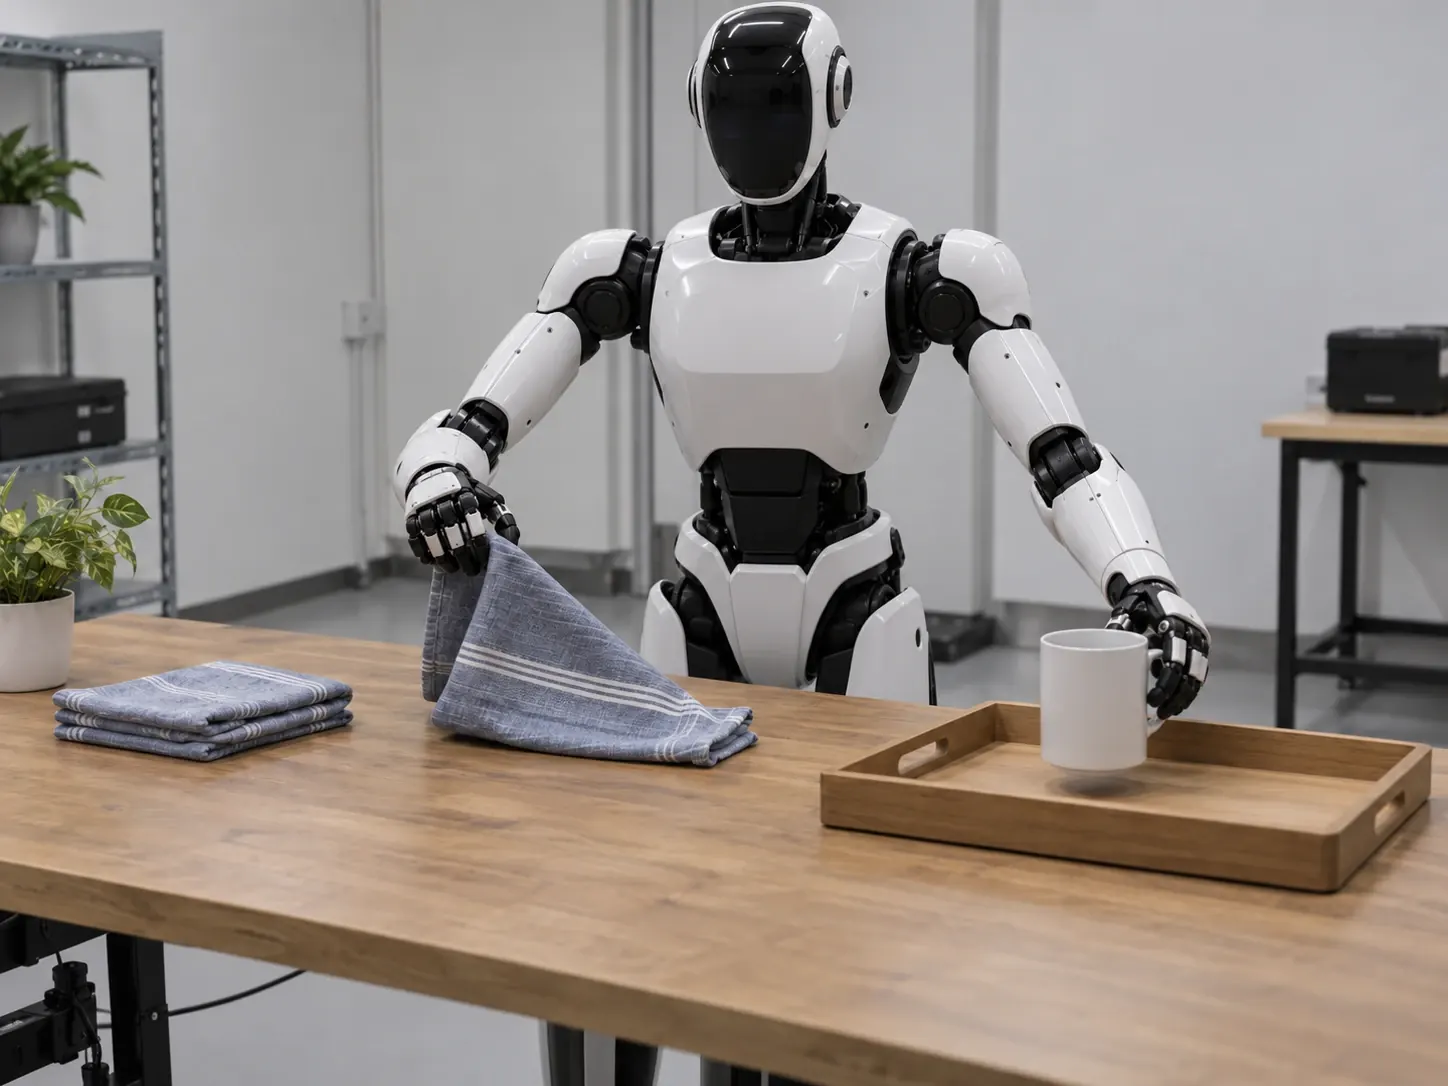
  5. A humanoid robot at a table folds a cloth and places a mug on a tray.
    Illustration

    05Generalising · 2022 to 2025

    One model, many tasks

    Models trained on large demonstration sets handle hundreds of tasks. RT-2 turns web knowledge into robot actions, and labs pool data across 22 robot types.

    Sources: RT-1, RT-2, Open X-Embodiment

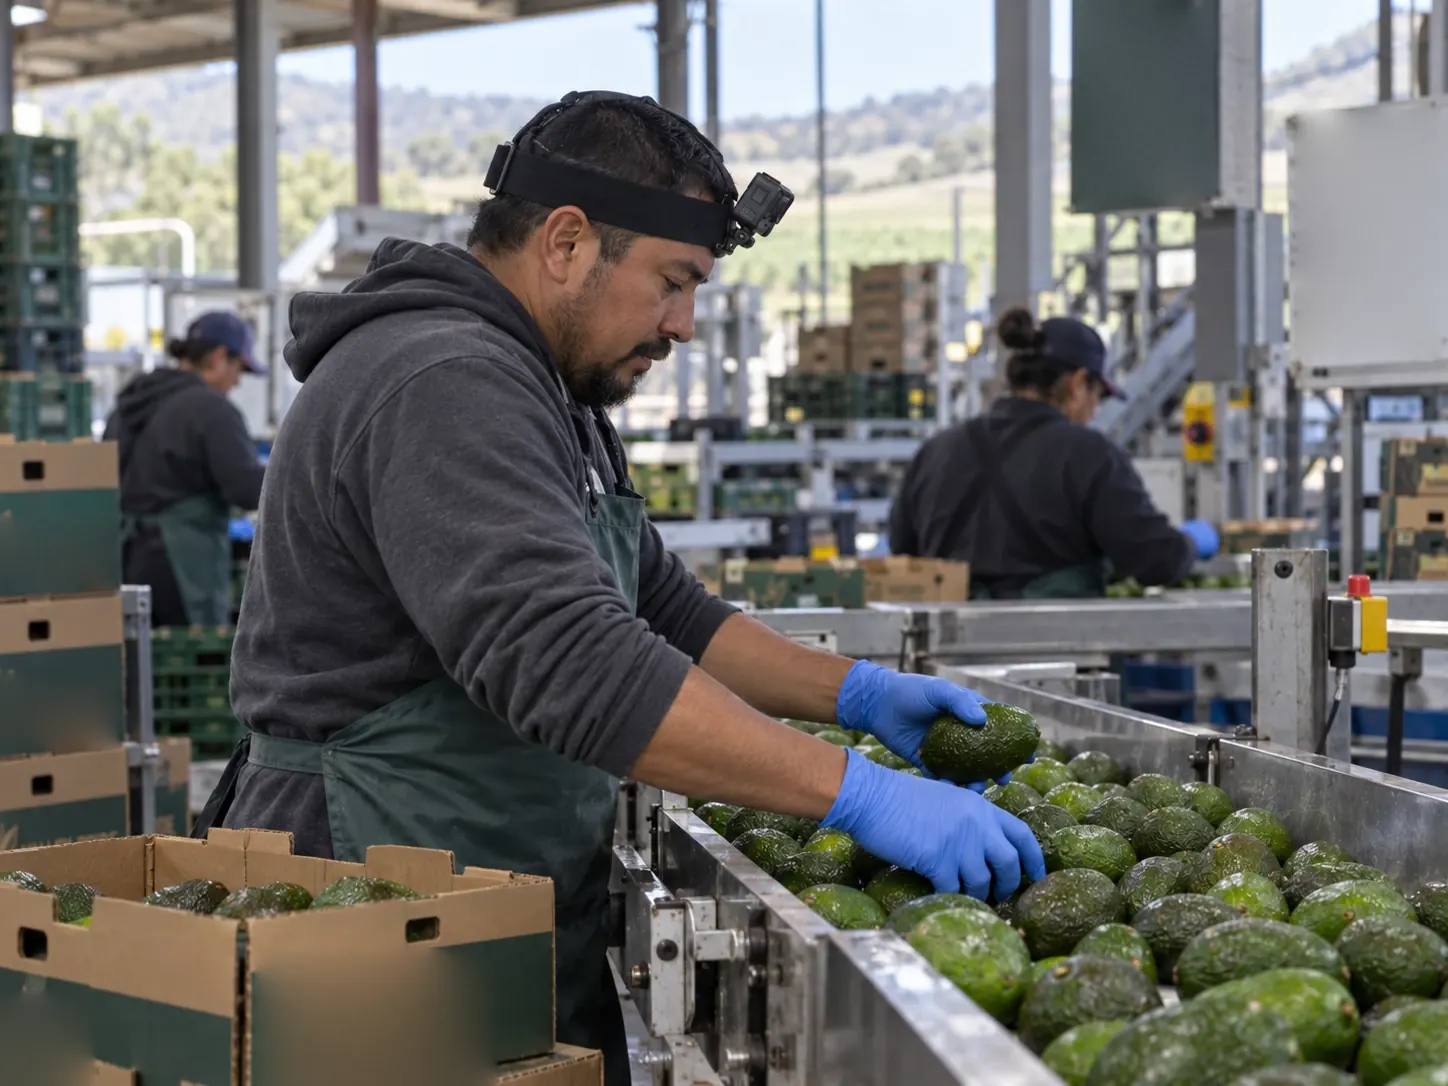
  6. A worker wearing a head-mounted camera sorts avocados on a packhouse line.
    Illustration

    06Experience · Now

    Robots need the real world

    Robots now have capable bodies, general models, simulation and capital. The gap is varied experience of real homes, shops, farms and workshops. In one 2026 test, a humanoid picked objects from a shelf 76% of the time and from the floor 46% of the time.

    • Bodies built at scale
    • Brains vision, language, action
    • Practice simulation
    • Capital $38bn market forecast for 2035
    • Experience slow and costly to gather

    Sources: Google DeepMind, Morgan Stanley, NVIDIA, Goldman Sachs forecast (2024). All sources
NovaCrest research

Where robots work today, and where the data needs to go

We mapped 7,594 physical tasks across 923 U.S. occupations against the robot systems cited for each one. Most of that evidence comes from places built around machines. Everyday workplaces are where real-world data has to go next.

of physical tasks have a robot rated able to do them somewhere
68%
in everyday workplaces built for people
16%
anywhere, as found, such as homes, farms and roads
1.4%
with no qualifying robot yet
32%
Explore the research

Built on Anthropic’s Economic Index robot exposure release (September 2026) and O*NET 29.3. Analysis by NovaCrest.

What we do today

Real-world task data, collected to your specification

Contributors wear a small head-mounted camera and carry out the tasks you define, so every recording shows the work from their own point of view. Our first operation runs in Ethiopia, led by the founders.

  1. 01SpecifyTasks, settings, format and the rules for an accepted recording
  2. 02CoordinateSites, contributors and schedules
  3. 03Consent and trainClear consent, then practice on your task
  4. 04CaptureFirst-person video of real work
  5. 05Check and deliverFirst checks, your format and a log of what you accept
  • Washing a cup
  • Folding laundry
  • Wiping a table
  • Putting away utensils
  • Cleaning a stove grate
Example first-person footage from head-mounted cameras

Where we are building

One route from specification to evaluation

A robotics team often coordinates recruiters, sites, hardware, consent, checks and labelling separately. We are building a single route through all of it, starting with the steps we run by hand today.

Software layer, plannedBuyer and operator portals · automated quality checks · API access

  1. SpecificationToday
  2. Sites and peopleToday
  3. CaptureToday
  4. Quality and rightsToday
  5. AnnotationPlanned
  6. DeliveryToday
  7. EvaluationPlanned

Running today

Specifications agreed with each team. Site and contributor coordination in Ethiopia. Head-mounted first-person capture. Consent records and first manual checks. Delivery in your format with a log of accepted recordings.

Building next

Buyer and operator portals. Automated quality checks. Annotation of actions, objects and task steps. API delivery. Support for real-world evaluation. More capture setups and locations.

Global direction

Every kind of place, every kind of task

Useful robot data reflects the variety of real work: different homes, workshops, farms, shops and warehouses, in different countries. Our network starts in Ethiopia and is designed to grow across Africa, Asia, Europe and the Americas.

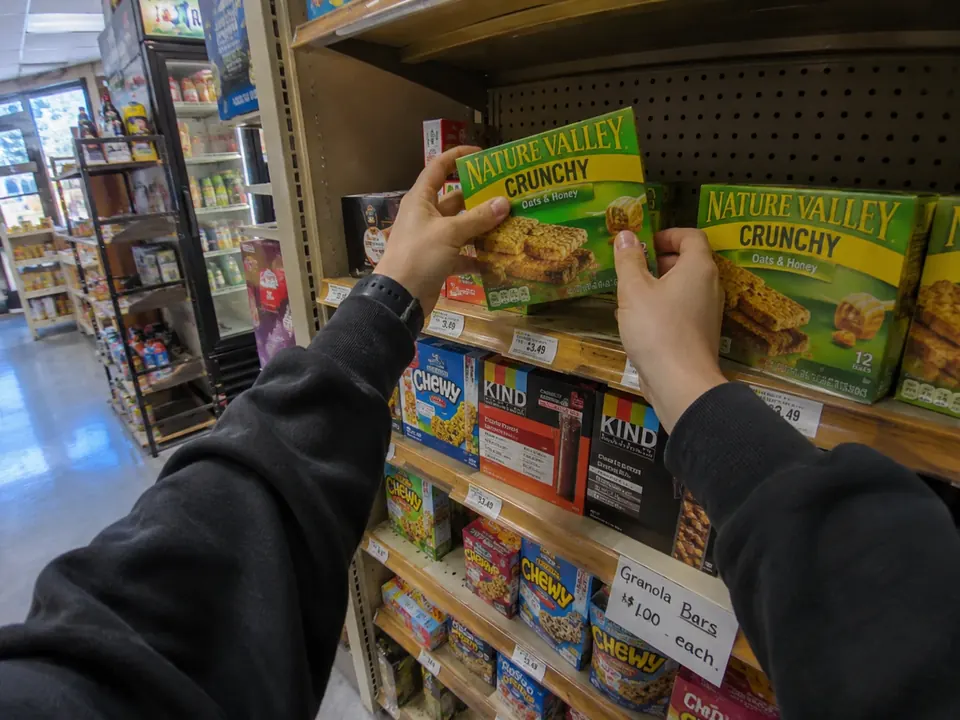
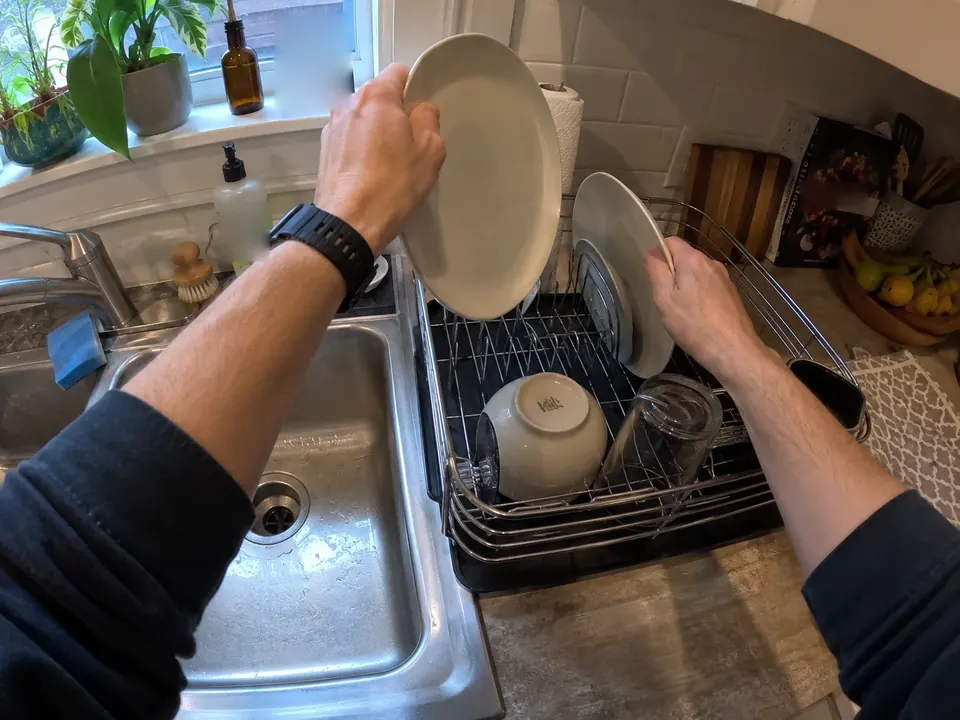
  • First-person view of hands loading plates into a dish rack beside a kitchen sink.HomesKitchen and household tasks
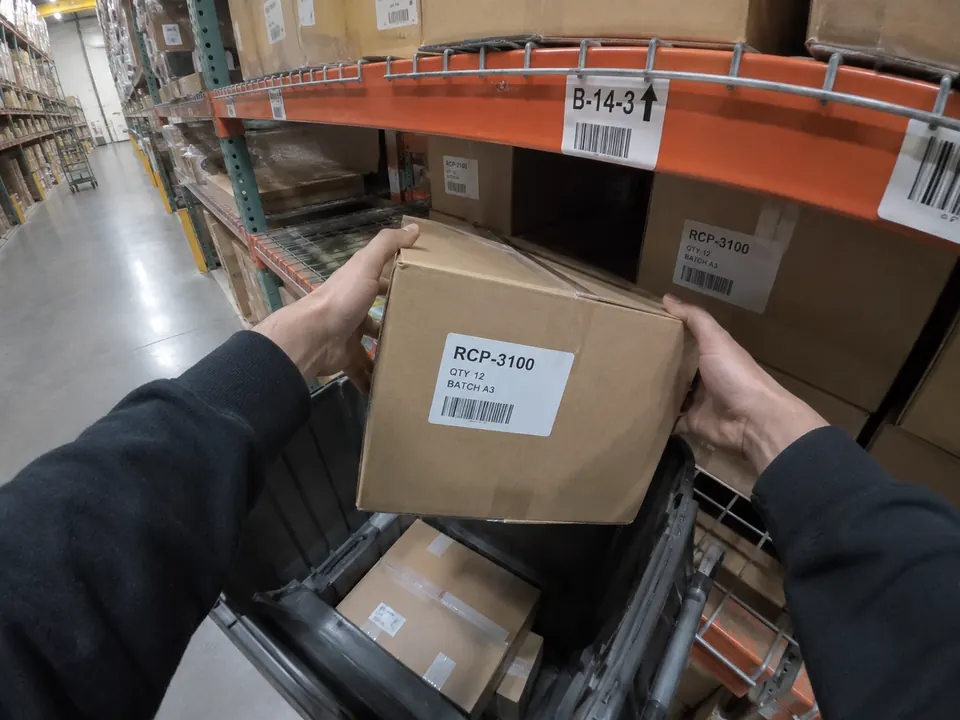
  • First-person view of hands lifting a labelled carton from a warehouse shelf into a tote.WarehousesPicking and packing
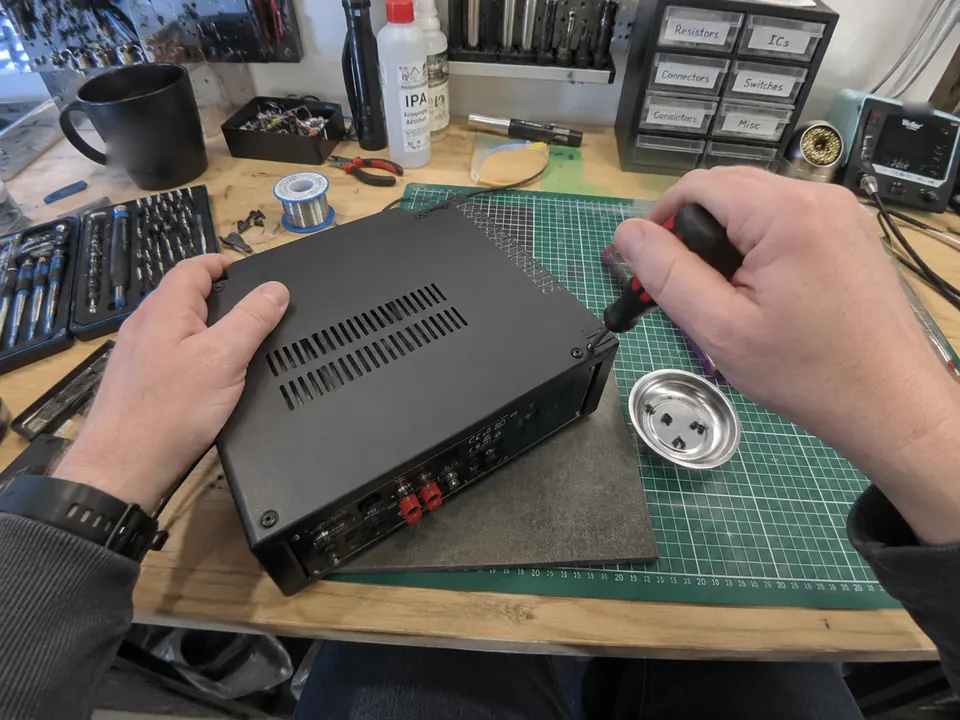
  • First-person view of hands unscrewing the case of an electronics unit on a repair bench.WorkshopsAssembly and repair
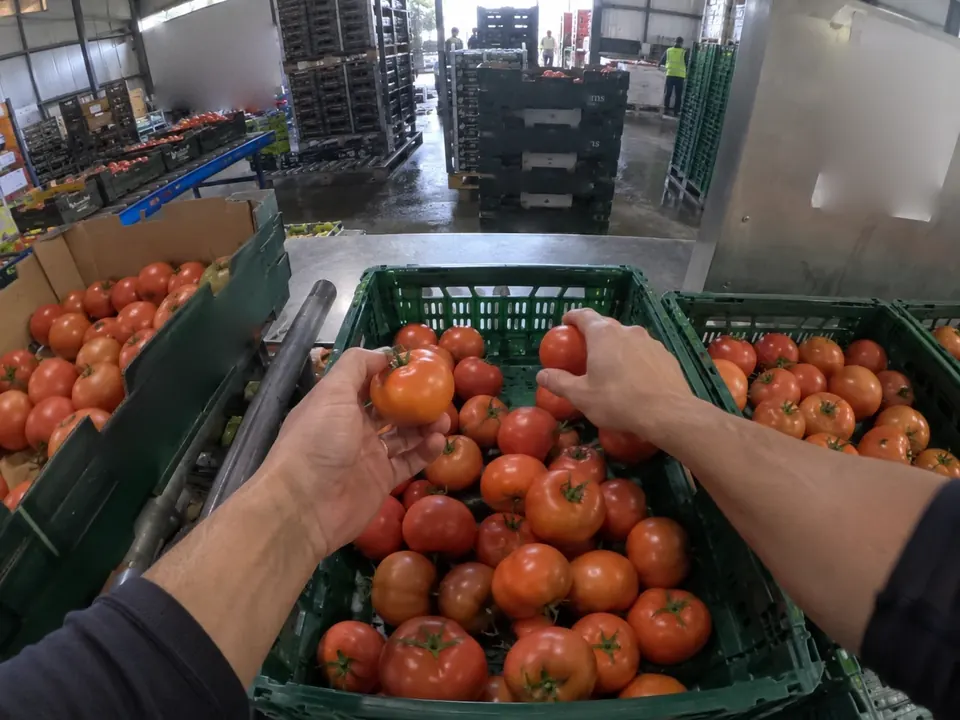
  • First-person view of hands sorting tomatoes into a crate in a packhouse.FarmsHarvest sorting and packing
  • First-person view of hands placing boxed goods on a shop shelf.ShopsStocking and handling goods
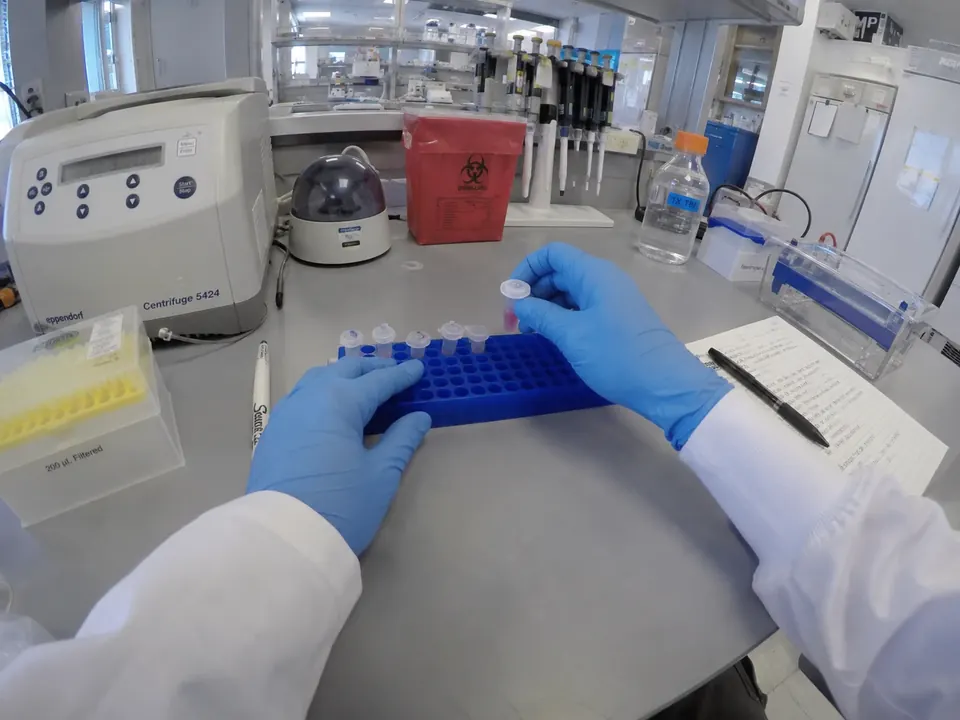
  • First-person view of gloved hands placing sample tubes into a rack on a lab bench.LabsCareful handling of samples

Illustrations of first-person capture in different workplaces.

  1. Operating nowAfricaEthiopia, our first operating location
  2. Expansion directionAsia
  3. Expansion directionEurope
  4. Expansion directionThe Americas

Founders

Why we are building NovaCrest

Robotics is one of the most important engineering problems of our time, and much of its progress now depends on experience of the physical world. Gathering that experience well takes people, trust, consent, careful checks and steady operations. We chose to build that capability from the ground up, starting with our own field work.

  • Natnael AlelgneCo-founder, partnerships and development
  • Garad NuireCo-founder, operations

Partnerships

For robotics teams and operating partners

Tell us what your robots need to learn, or how your organisation could host or run collection work. We reply with practical questions and an honest view of fit.

Robotics and model teams
Tasks, settings, data format, quantity and timing.
Operating partners
Sites, organisations and coordinators interested in collection work.

Tasks, settings, format, quantity and timing all help.

We use your details only to reply to this enquiry.